An interactive research sketch
Perceive.
Reason.
Act.
Four distinct studies: stack and unstack objects, explore a dexterous hand, command a mobile robot, or predict the consequence of a physical impulse.
These are illustrative kinematics and idealized dynamics, not learned policies or experimental results.
Read the research context ↗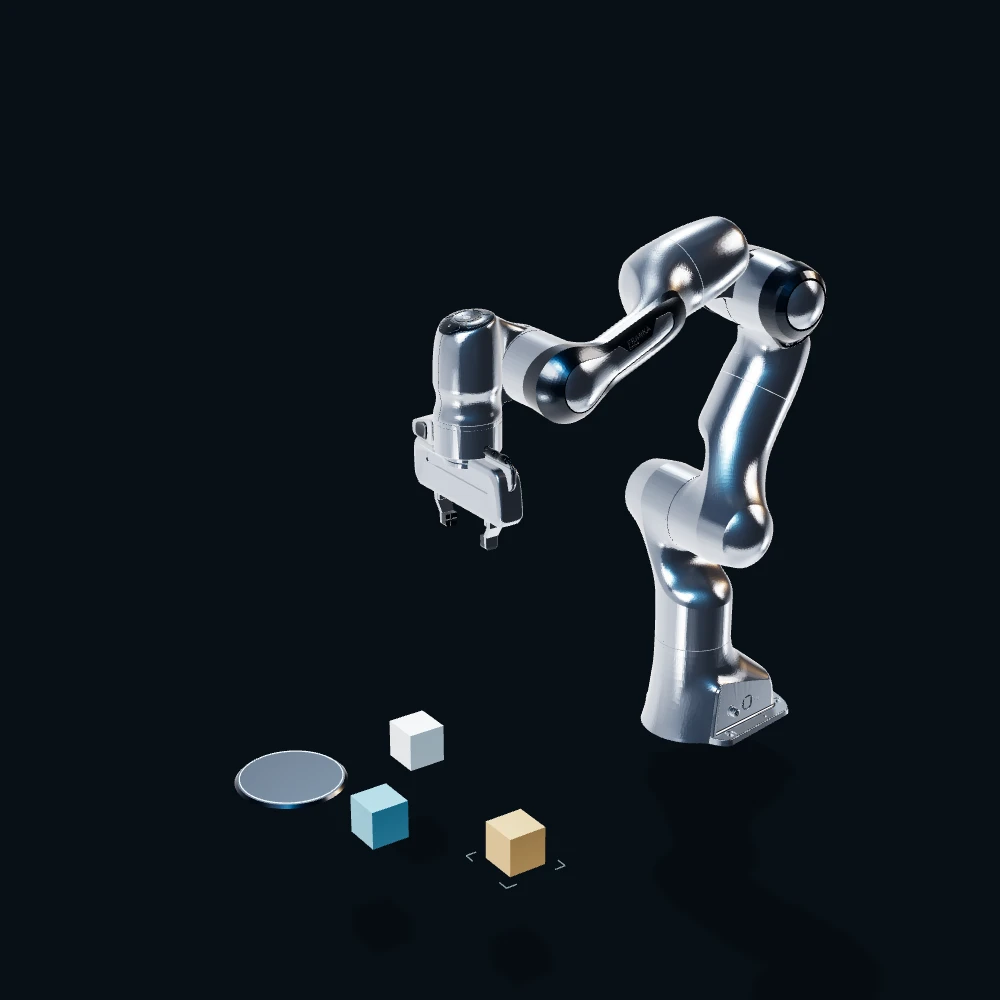
01 / Agentic robotics
A goal becomes a gesture.
Choose an object. Watch the arm reach, grasp and place it.
Click an object or run a grasp · drag to orbit
Illustrative kinematics · not a learned policyResearch context ↗